Vehicle integration
Hadal’s vehicle interface architecture is designed to connect heterogeneous underwater systems through standardized software adapters while preserving vehicle state, telemetry and mission context.
Platform capabilities
Hadal’s platform architecture is designed around the technical functions required to connect, understand and operate across increasingly complex subsea missions.
A connected capability model
Vehicles, sensors, infrastructure records, observations and operational decisions become more useful when they can be understood as connected mission context.
Hadal’s vehicle interface architecture is designed to connect heterogeneous underwater systems through standardized software adapters while preserving vehicle state, telemetry and mission context.
A shared geospatial operating environment designed to organize active missions, vehicles, assets and operational events.
A common context for combining navigation, sonar, imagery and other mission-derived information.
Structured mission context designed to support prioritization, operational review and decision-making.
Asset-centered inspection and mission history for subsea infrastructure.
Operator-facing analysis designed to help surface anomalies, priorities and relevant mission context.
Structured relationships among missions, assets, observations and evidence to support traceable investigation and review.
A path toward richer digital-twin and reconstruction workflows for infrastructure and mission environments.
Product evidence
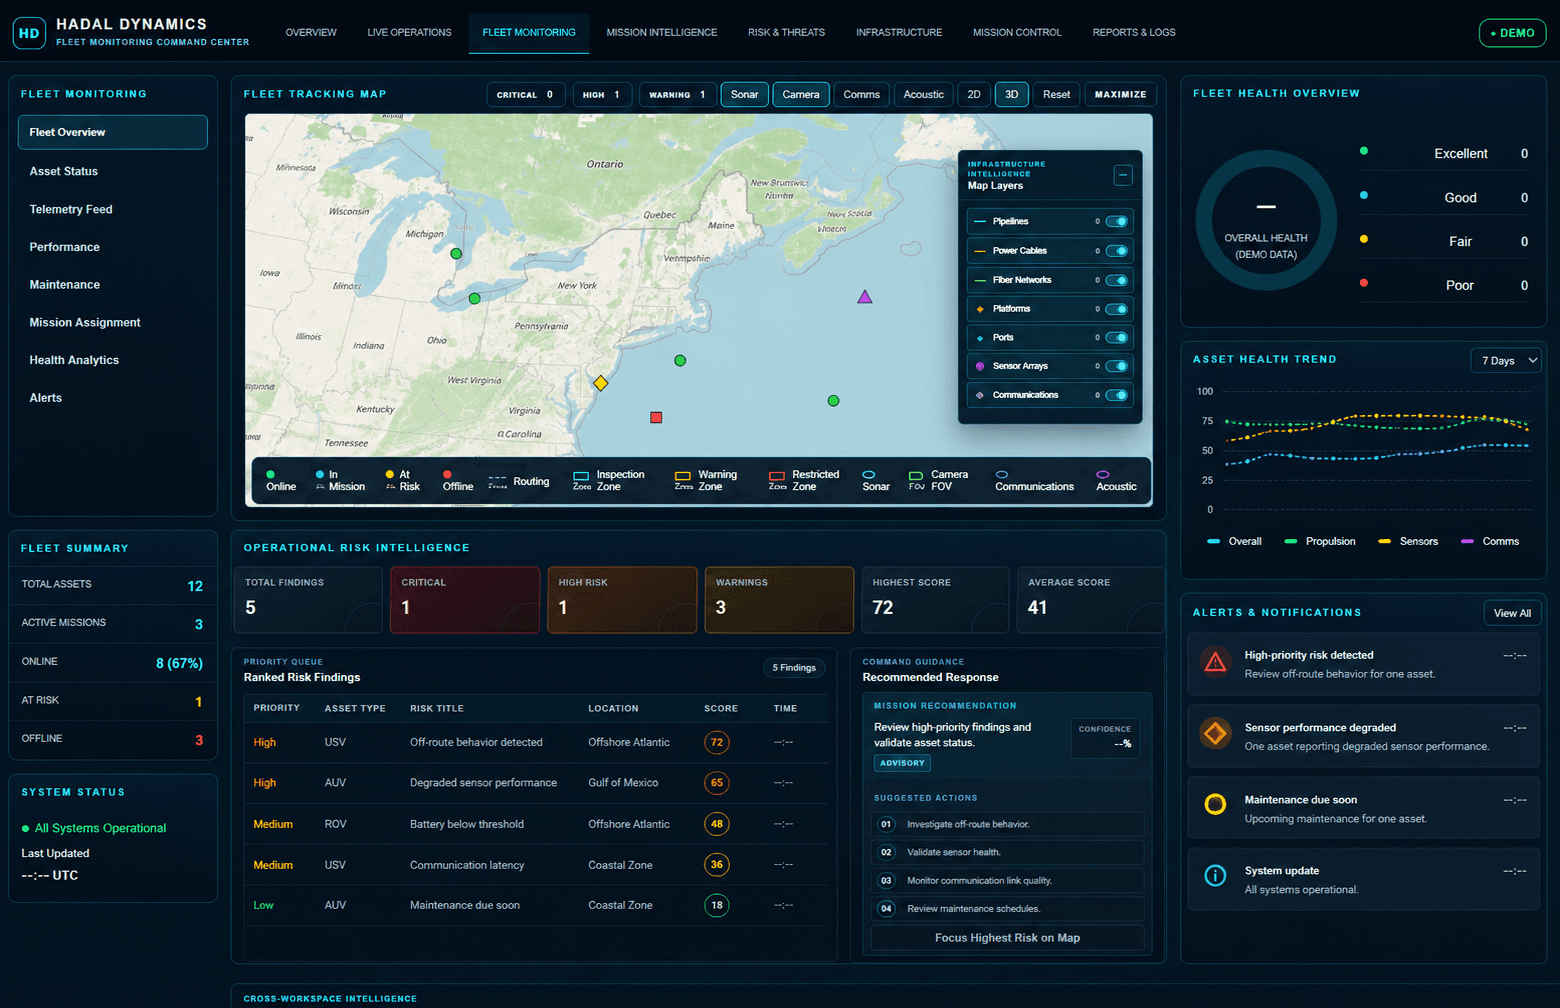
Fleet Monitoring connects vehicle position, health, mission assignment, alerts and risk context in one representative interface.