Vehicle connectivity
Standardized software interfaces designed to connect heterogeneous underwater platforms while preserving vehicle and mission state.
The Hadal platform
Hadal Dynamics is building an operational software layer that connects vehicles, mission context, geospatial awareness, infrastructure information and sensor-derived intelligence.
Platform architecture
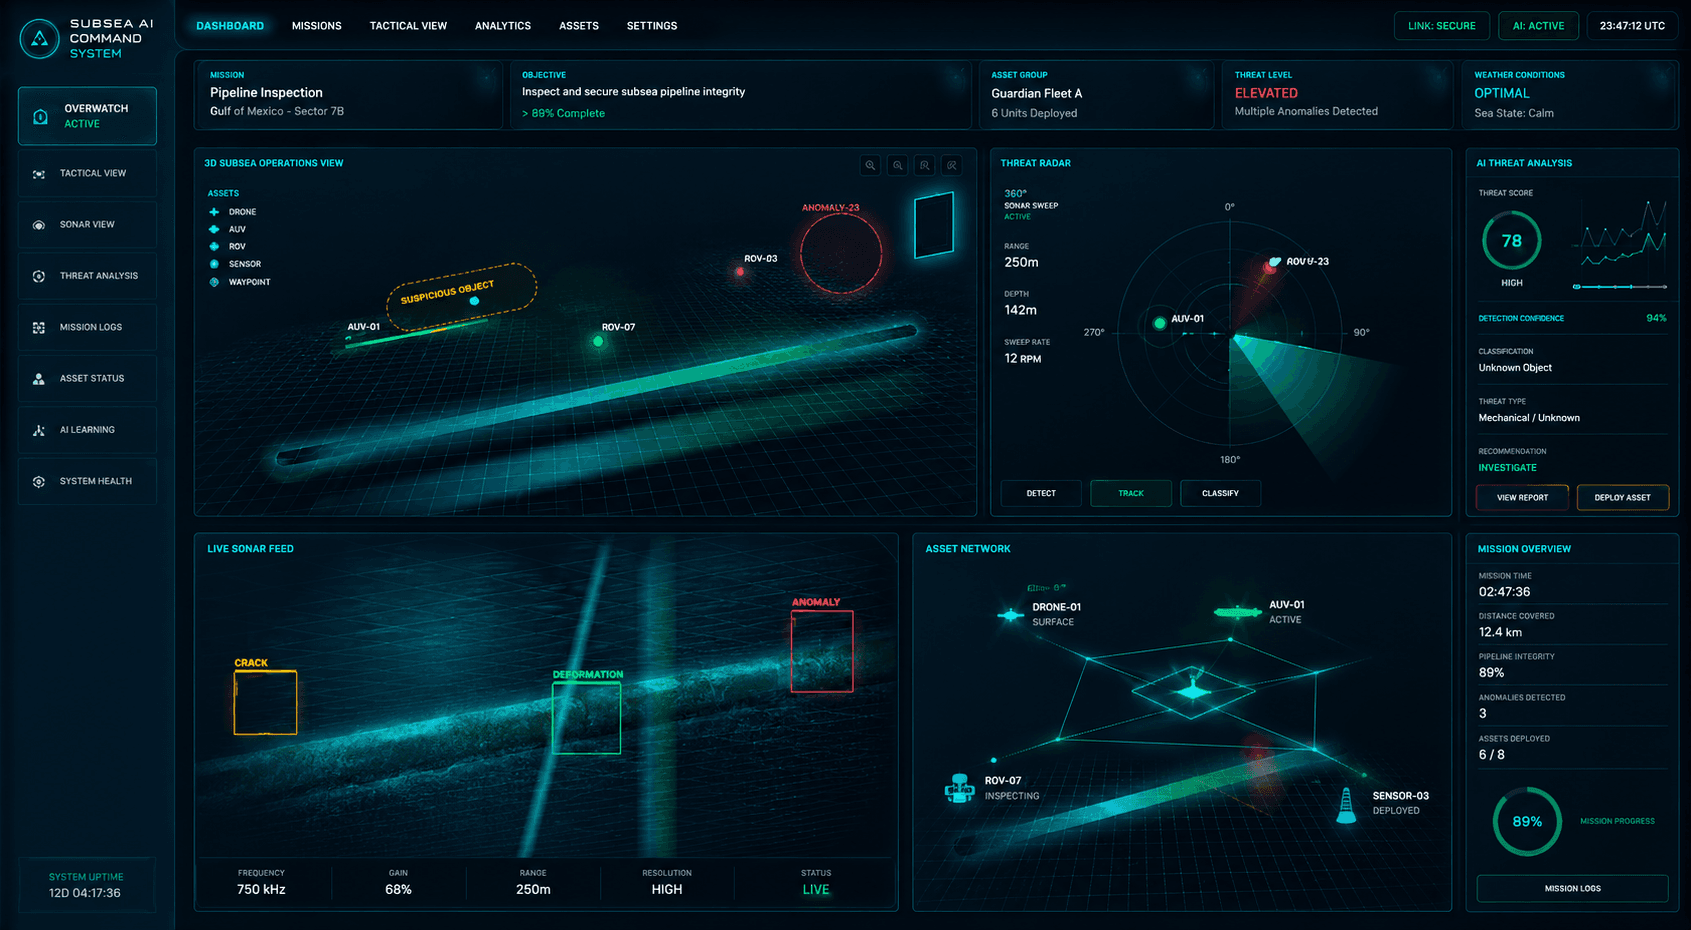
The platform is being developed as a common environment rather than a mission-specific point solution or a dependency on any single hardware platform.
Standardized software interfaces designed to connect heterogeneous underwater platforms while preserving vehicle and mission state.
A shared structure for missions, vehicles, assets, events and operational timelines.
Spatial mission context designed to connect active operations with the environments and assets below the surface.
Navigation, sonar, imagery and other mission-derived information organized within a common operational context.
Asset-centered inspection history, observations and geospatial understanding for critical subsea systems.
Operator-facing workflows being developed to surface priorities, anomalies and relevant mission information.
Traceable relationships among missions, observations, source records and outcomes for investigation and review.
Software-first subsea operations
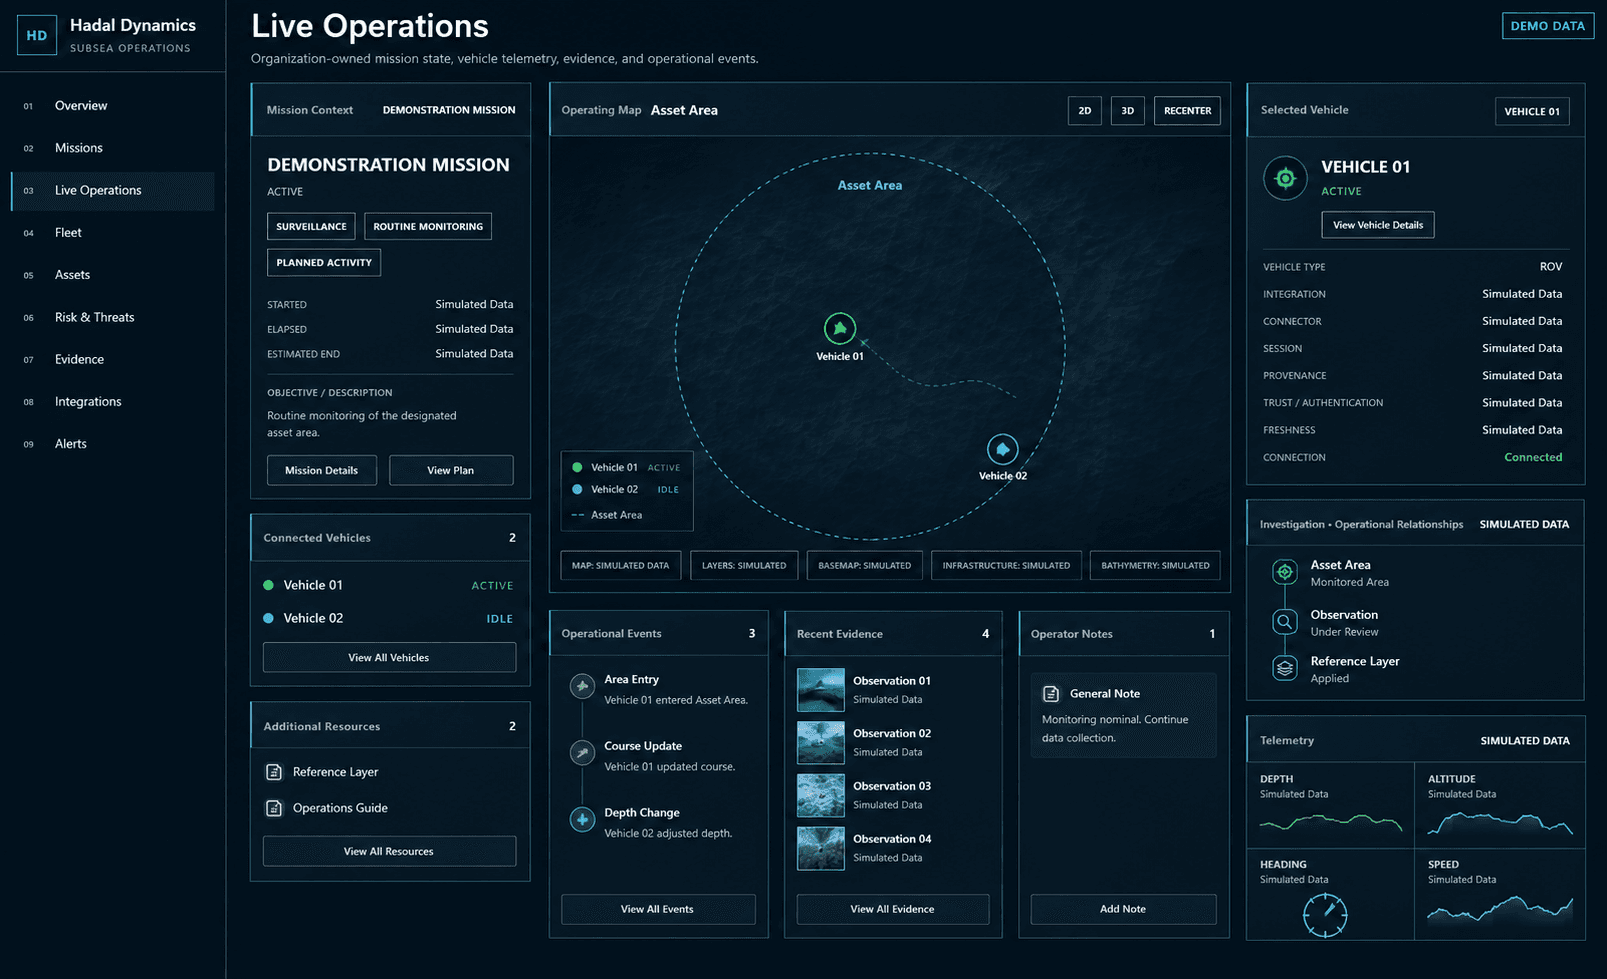
Live Operations brings mission context, vehicles, geospatial awareness, evidence and telemetry into one representative operational view.